INGLÉS
FEEDBACK CONTROL OF DYNAMIC BIPEDAL ROBOT LOCOMOTION
-5% de dto. exclusivo web
Envío gratis
Entrega aproximada en 2/3 semanas.
No tenemos stock, pero lo pedimos urgente al distribuidor, te lo enviamos en 24h cuando lo recibamos en nuestro almacén, en ocasiones los distribuidores no pueden servirnos el producto, en este caso anularemos el pedido y te informaremos. El importe lo cobramos sólo en el momento en el que hagamos el envío.
Otros vendedores (nuevo y usado) desde 189,00 €
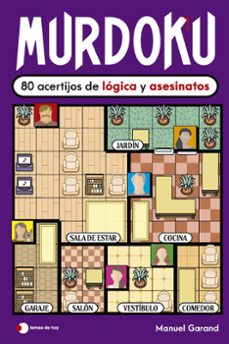
Descubre por qué Murdoku es el libro más viral
Resuelve estos adictivos casos gracias de tu ingenio e imaginación. Deberás completar la cuadrícula valiéndote de todos los elementos a tu disposición: personajes, habitaciones, muebles, animales, objetos… Cualquier detalle podría ser clave en la investigación. ¿SERÁS CAPAZ DE CONVERTIRTE EN UN DETECTIVE EXPERTO Y RESOLVERLOS TODOS?
Sinopsis
Bipedal locomotion is among the most difficult challenges in control engineering. Most books treat the subject from a quasi-static perspective, overlooking the hybrid nature of bipedal mechanics. Feedback Control of Dynamic Bipedal Robot Locomotion is the first book to present a comprehensive and mathematically sound treatment of feedback design for achieving stable, agile, and efficient locomotion in bipedal robots. In this unique and groundbreaking treatise, expert authors lead you systematically through every step of the process,including: mathematical modeling of walking and running gaits in planar robots; analysis of periodic orbits in hybrid systems; design and analysis of feedback systems for achieving stable periodic motions; algorithms for synthesizing feedback controllers; detailed simulation examples; and, experimental implementations on two bipedal test beds.The elegance of the authors'' approach is evident in the marriage of control theory and mechanics, uniting control-based presentation and mathematical custom with a mechanics-based approach to the problem and computational rendering.Concrete examples and numerous illustrations complement and clarify the mathematical discussion. A supporting Web site offers links to videos of several experiments along with MATLAB[registered] code for several of the models. This one-of-a-kind book builds a solid understanding of the theoretical and practical aspects of truly dynamic locomotion in planar bipedal robots.
Ficha Técnica
Editorial: Crc Press
ISBN: 9781420053722
Idioma: Inglés
Número de páginas: 524
Encuadernación: Tapa dura
Fecha de lanzamiento: 26/06/2007
Año de edición: 2007
Plaza de edición: Usa
Alto: 23.0 cm
Ancho: 16.0 cm
Especificaciones del producto
Reseñas sobre FEEDBACK CONTROL OF DYNAMIC BIPEDAL ROBOT LOCOMOTION
Comparte tu experiencia con la comunidad lectora.
0 Reseñas
5 0
4 0
3 0
2 0
1 0
Sólo por opinar entras en el sorteo mensual de tres tarjetas regalo valoradas en
20€
Publicar una opinión supone haber leído y aceptado las
bases del sorteo
"Tu opinión tiene premio".
Los libros más vendidos de Robótica